
I am a Research Associate in the Safe AI Lab at Carnegie Mellon University, working with Prof. Ding Zhao. I also serve as the Associate Director of the ETAIC (Embodied Technology for Autonomy, Intelligence, and Control) Lab at the University of Texas at Arlington, working with Prof. Eric Tseng, a member of the National Academy of Engineering. Previously, I was a Research Fellow at Tsinghua University and a Visiting Researcher at University College London. I received my Ph.D. from the School of Vehicle and Mobility at Tsinghua University, under the supervision of Prof. Zhi Wang and Prof. Shengbo Eben Li, where I received Tsinghua’s Outstanding Doctoral Dissertation Award and Outstanding Ph.D. Graduate Award.
My research focuses on learning and control for self-improving physical systems, particularly human–robot interaction (HRI). I study stable policy learning and skill transfer for safe human–robot collaboration, combining multi-agent reinforcement learning theory, game-theoretic coordination, and vision–language models integrated with closed-loop control. My broader goal is recursive self-improvement: enabling robots to improve how they learn while respecting physical and safety constraints. My learning-based control systems have been applied to human–robot collaboration with General Motors and intelligent vehicle control with BYD Auto, Dongfeng Motor, SAIC Motor.
I have authored over 50 peer-reviewed papers in SCI-indexed journals and conference proceedings. I serve as Guest Editor for several journals and Associate Editor on the International Program Committees of conferences including IEEE ITSC and IEEE IV. I welcome research collaborations and inquiries from prospective research assistants and volunteers interested in working with me at the Safe AI Lab and ETAIC Lab.
💻 Research Interests
- Physical AI Theory: reinforcement learning and control, learning stability and safety, and game theory.
- Robotics Applications: whole-body control, loco-manipulation, human-robot interaction, and sim-to-real transfer.
- Mobility Applications: reinforcement learning for autonomous/electric vehicles, safety evaluation, and digital twins.


🔥 News
- 2026.09: 🎉 Our paper Intention-Aware Adversarial Multi-Agent Reinforcement Learning for Autonomous Vehicle Stress Testing received the Best Paper Award at International Symposium on Advanced Vehicle Control (AVEC) 2026.
- 2026.06: Our paper IO-WBC: Interaction-Orientated Whole-Body Control for Compliant Object Transport was accepted at IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026.
- 2026.06: Our paper Learning Versatile Humanoid Manipulation with Touch Dreaming was accepted at IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026.
- 2026.04: 🎉 Our paper Learning Human-Robot Collaboration via Heterogeneous-Agent Lyapunov Policy Optimization was accepted and selected for an Oral Presentation (top 0.7%) at International Conference on Machine Learning (ICML) 2026.
- 2026.01: I serve as an Associate Editor for the upcoming IEEE International Conference on Intelligent Transportation Systems (ITSC 2026). I warmly welcome you to submit your papers to this exciting venue.
- 2025.10: Our paper Multi-Scale Reinforcement Learning of Dynamic Energy Controller for Connected Electrified Vehicles was published in IEEE Transactions on Intelligent Transportation Systems.
- 2025.10: I serve as an Associate Editor for the upcoming IEEE Intelligent Vehicles Symposium (IV 2026). I warmly welcome you to submit your papers to this exciting venue.
- 2025.06: Our paper Bi-Level Transfer Learning for Lifelong-Intelligent Energy Management of Electric Vehicles was published in IEEE Transactions on Intelligent Transportation Systems.
- 2025.06: 🎉 I joined the Safe AI Lab as a Research Associate at CMU in the U.S.
- 2025.01: Our paper Theory-Constrained Neural Network with Modular Interpretability for Fuel Cell Vehicle Modelling was published in IEEE Transactions on Vehicular Technology.
- 2024.11: 🎉 I am an incoming Associate Director of ETAIC Lab led by Prof. Eric Tseng (NAE Member) at UTA in the U.S.
- 2024.08: I delivered a plenary talk at 2024 China SAE Annual Conference on Advanced Powertrains (APC), titled “Data-Driven Modeling of Electric Powertrains and Reinforcement Learning-Based Optimal Control”, held in Zhenjiang, China.
- 2024.06: 🎉 I received Outstanding Doctoral Dissertation Award, the Outstanding Ph.D. Graduate, and the “Shuimu Scholar” Fellowship from Tsinghua University.
- 2024.06: Our paper Integrated Thermal and Energy Management of Connected Hybrid Electric Vehicles Using Deep Reinforcement Learning was published in IEEE Transactions on Transportation Electrification.
💬 Media

Academic Talk
Research at the intersection of learning, control, and robotics for safe and capable intelligent systems in the physical world.
Watch Video →
Institutional Feature
Selected research featured by academic institutions, highlighting advances in learning, robotics, and embodied intelligence.
Read Feature →Recent Talks
- 2026.09, Oral Presentation, IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026, “Interaction-Orientated Whole-Body Control for Compliant Object Transport”, Pittsburgh, USA
- 2026.09, Invited Talk, China SAE - Young Scholars Frontier Forum, “Learning, Control, and Games for Trustworthy Embodied Intelligence”, China Society of Automotive Engineers (CSAE), Online
- 2026.09, Oral Presentation (Best Paper Award), International Symposium on Advanced Vehicle Control (AVEC) 2026, “Intention-Aware Adversarial Multi-Agent Reinforcement Learning for Autonomous Vehicle Stress Testing”, Tsukuba, Japan
- 2026.07, Oral Presentation, International Conference on Machine Learning (ICML) 2026, “HALO: Learning Human-Robot Collaboration via Heterogeneous-Agent Lyapunov Policy Optimization”, Seoul, South Korea
- 2024.08, Plenary Talk, APC 2024: Joint Annual Conference on Advanced Powertrains - China SAE, “Data-Driven Modeling of Electric Vehicles and Reinforcement Learning-Based Optimal Control”, China SAE, Zhenjiang, China
- 2024.05, Seminar Talk, “Reinforcement Learning-based Control and Policy Transfer for Connected Electric Vehicles”, Tsinghua University, Beijing, China
📝 Featured Publications
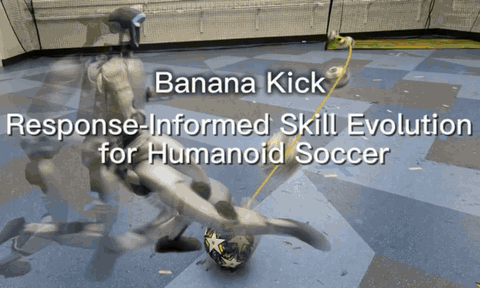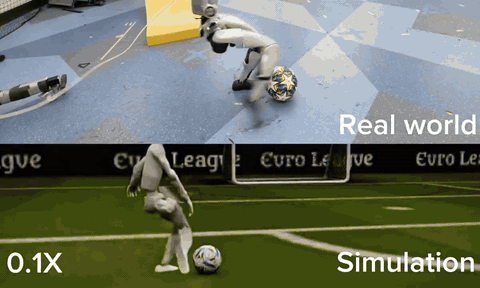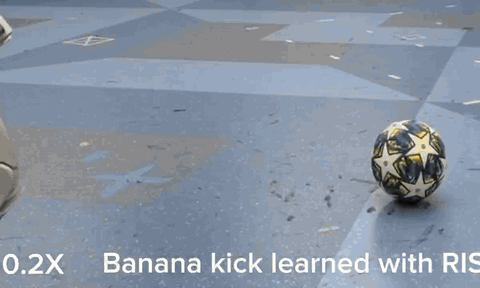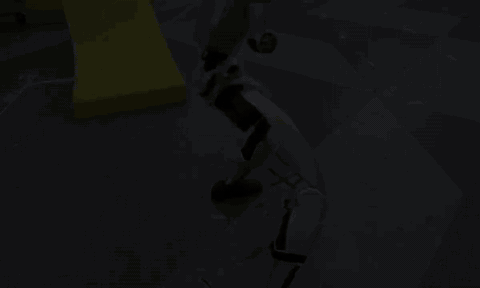
Banana Kick: Response-Informed Skill Evolution for Humanoid Soccer
Hao E. Zhang, Ruize Geng, Raihan Haque, Khalil Zbiss, Guanyang Luo, Hui-ping Wang, H. Eric Tseng, Ding Zhao
Submitted to the IEEE
- We propose response-informed skill evolution (RISE), a closed-loop objective-continuation method for policy adaptation. RISE evolves the ordinary kick into a high-spin curved kick with 11.55 rad/s mean ball spin.

Learning Human-Robot Collaboration via Heterogeneous-Agent Lyapunov Policy Optimization
Hao E. Zhang, Yaru Niu, Yikai Wang, Ding Zhao, H. Eric Tseng
ICML 2026 Oral Presentation (top 0.7%)
- We propose heterogeneous-agent Lyapunov policy optimization (HALO), which establishes formal stability directly in the policy-parameter space by enforcing a per-step Lyapunov decrease condition on a parameter-space disagreement metric.

IO-WBC: Interaction-Orientated Whole-Body Control for Compliant Object Transport
Hao E. Zhang, Yves Tseng, Ding Zhao, H. Eric Tseng
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026
- We proposed a bio-inspired, interaction-oriented whole-body control (IO-WBC) that functions as an artificial cerebellum - an adaptive motor agent that translates upstream (skill-level) commands into stable, physically consistent whole-body behavior under contact.
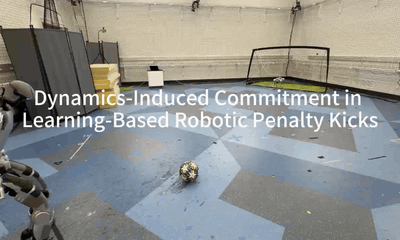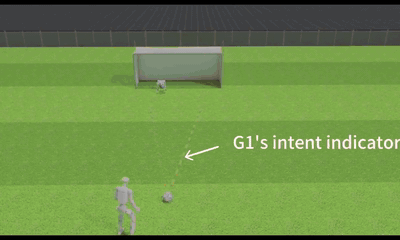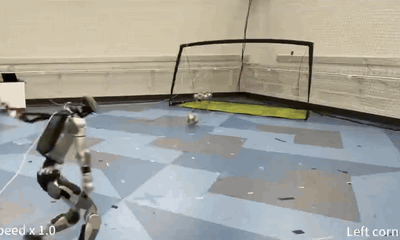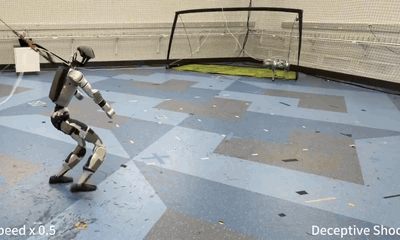
Dynamics-Induced Commitment in Learning-Based Robotic Penalty Kicks
Ruize Geng, Hao E. Zhang (Co-Frist & Corresponding Author; Project Lead), Yisen Li, Yikai Wang, H. Eric Tseng, Ding Zhao
Submitted to the IEEE
- We introduce dynamics-induced commitment mapping (DIC-Map), a body-grounded framework that identifies when physical dynamics eliminate strategic alternatives in robotic games, revealing how embodiment fundamentally shapes learning and decision making in humanoid-quadruped penalty kicks.
SAGE: Safety-Aligned Gradient Enforcement for Human-Robot Collaboration
Yisen Li, Hao E. Zhang (Co-Frist & Corresponding Author; Project Lead), Ruize Geng, Yves Tseng, Ding Zhao, H. Eric Tseng
Submitted to the IEEE
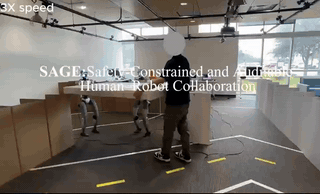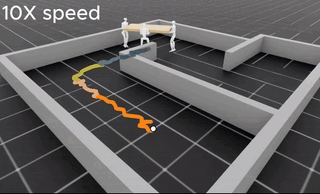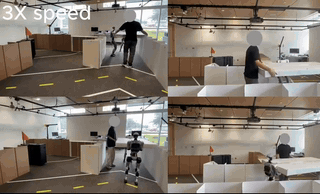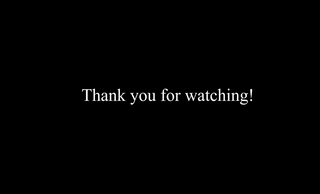
- We propose safety-aligned gradient enforcement (SAGE), which aligns interpretable multi-agent policy learning with safety-constrained execution through differentiable safety internalization and Lyapunov-regulated team-aware policy updates, enabling safe physical collaboration between multiple humanoid robots and humans.
KPI: A Promptable Kernel for Physical Interaction on Humanoids
Yikai Wang, Honghao Zhu, Xiao Hu, Hao E. Zhang, Zelin Wang, Yip Fun Yeung, Ding Zhao, Lingfeng Sun
Submitted to the IEEE
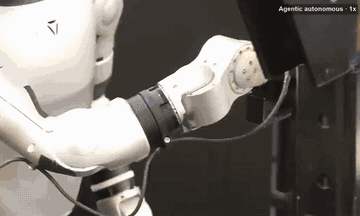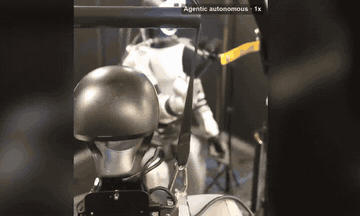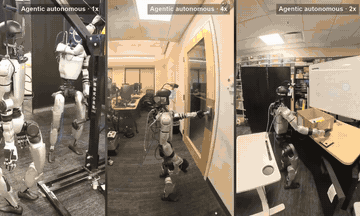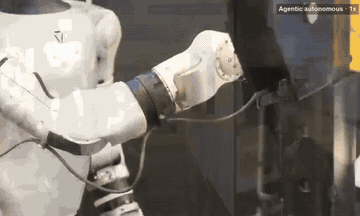
- We present KPI, a promptable kernel for physical interaction on humanoid robots that adapts arm impedance and feedforward control to task-specific interaction requirements. KPI enables versatile physical tasks such as winch operation, door opening, and box transport without task-specific control code.
Anticipatory Robot Goalkeeping via Monotone Optimal Stopping
Hao E. Zhang, Ruize Geng, Yisen Li, Yaru Niu, Yikai Wang, Raihan Haque, Khalil Zbiss, Guanyang Luo, Hui-ping Wang, H. Eric Tseng, Ding Zhao
Submitted to the IEEE
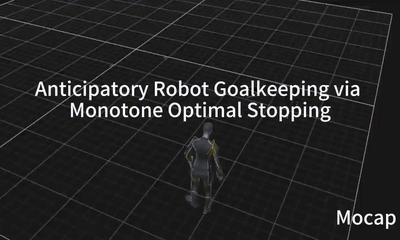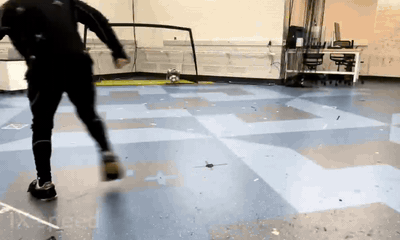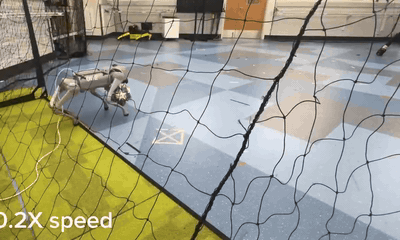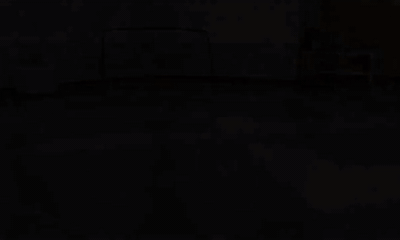
- We formulate anticipatory robotic interception as a finite-horizon optimal stopping problem and propose monotone optimal stopping (MOS), allowing a quadruped goalkeeper to decide when to act before shot intent is fully resolved while retaining closed-loop adaptation to deceptive direction changes.

C2C: A Cognition-to-Control Hierarchy for Human-Robot Collaboration via Multi-Agent Learning
Hao E. Zhang, Yisen Li, Ruize Geng, Yves Tseng, Yaru Niu, Ding Zhao, H. Eric Tseng
Submitted to the IEEE
- In multi-agent human-robot collaboration, where long-horizon coordination decisions and physical execution must co-evolve under contact, feasibility, and safety constraints. We address this limitation with cognition-to-control (C2C), a three-layer hierarchy that makes the deliberation-to-control pathway explicit.

Learning Versatile Humanoid Manipulation with Touch Dreaming
Yaru Niu, Zhenlong Fang, Binghong Chen, Shuai Zhou, Revanth Senthilkumaran, Hao E. Zhang, Bingqing Chen, Chen Qiu, Eric H. Tseng, Jonathan Francis, Ding Zhao
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026
- We develop a VR-based whole-body data collection system and propose Humanoid Transformer with Touch Dreaming (HTD), a multimodal Transformer that jointly models vision, proprioception, and touch, achieving a 90.9% relative improvement in average success rate across five real-world tasks.

Multi-Scale Reinforcement Learning of Dynamic Energy Controller for Connected Electrified Vehicles
Hao E. Zhang, Nuo Lei, Shengbo Eben Li, Junzhi Zhang, Zhi Wang
In IEEE Transactions on Intelligent Transportation Systems
- We proposed a multi-horizon reinforcement learning (MHRL) featuring a novel state representation and coordinated training of sub-networks across multiple time scales, which greatly improves fuel economy in real-world driving.

Bi-Level Transfer Learning for Lifelong-Intelligent Energy Management of Electric Vehicles
Hao E. Zhang, Nuo Lei, Wang Peng, Bingbing Li, Shujun Lv, Boli Chen, Zhi Wang
In IEEE Transactions on Intelligent Transportation Systems
Industrial Collaborator: BYD Auto
- We proposed a bi-level transfer approach with MAML to realize cross-platform transferable and online-adaptive EMS for REEVs. It contributed to the successful industry deployment of RL methods, implemented in leading automotive company - BYD Auto, significantly enhancing the REEV efficiency.
Book Chapters
- Hao E. Zhang, H. Eric Tseng. “Foundations of Human-Aware, Intention-Informed Stress Testing for Autonomous Vehicles.” Advances in Intelligent Vehicles in the Era of AI. Institution of Engineering and Technology (IET), To be published.
- Bin Shuai*, Hao E. Zhang* (Co-first Author), Min Hua, Beiyan Jiang, Zhi Wang, Shengbo Eben Li. “Model-free reinforcement learning for integrated energy control of hybrid road vehicles.” Physics-Aware Machine Learning for Integrated Energy Systems Management. Elsevier, 2025. 299-331.
Selected Papers
- Hao E. Zhang, Yaru Niu, Yikai Wang, Ding Zhao, H. Eric Tseng. HALO: Learning Human-Robot Collaboration via Heterogeneous-Agent Lyapunov Policy Optimization. International Conference on Machine Learning (ICML), 2026. Oral Presentation, top 0.7%.
- Hao E. Zhang, Yves Tseng, Ding Zhao, H. Eric Tseng. IO-WBC: Interaction-Orientated Whole-Body Control for Compliant Object Transport. IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026, Oral Presentation.
- Hao E. Zhang, Ruize Geng, Raihan Haque, Khalil Zbiss, Guanyang Luo, Hui-ping Wang, H. Eric Tseng, Ding Zhao. Banana Kick: Response-Informed Skill Evolution for Humanoid Soccer. IEEE International Conference on Robotics and Automation (ICRA), 2027, Submitted.
- Hao E. Zhang, H. Eric Tseng. Intention-Aware Adversarial Multi-Agent Reinforcement Learning for Autonomous Vehicle Stress Testing. International Symposium on Advanced Vehicle Control (AVEC), 2026, Oral Presentation, Best Paper Award.
- Yaru Niu, Zhenlong Fang, Binghong Chen, Shuai Zhou, Revanth Senthilkumaran, Hao E. Zhang, Bingqing Chen, Chen Qiu, H. Eric Tseng, Jonathan Francis, Ding Zhao. Learning Versatile Humanoid Manipulation with Touch Dreaming. IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026, Oral Presentation.
- Hao E. Zhang, Yisen Li, Ruize Geng, Yves Tseng, Yaru Niu, Ding Zhao, H. Eric Tseng. Physical Contracts for Plug-Compatible Human–Humanoid Collaboration. IEEE International Conference on Robotics and Automation (ICRA), 2027, Submitted.
- Hao E. Zhang, Nuo Lei, Shengbo Eben Li, Junzhi Zhang, Zhi Wang. Multi-Scale Reinforcement Learning of Dynamic Energy Controller for Connected Electrified Vehicles. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(12): 22607–22619. (IF: 9.1)
- Ruize Geng, Hao E. Zhang* (Co-first Author), Yisen Li, Yikai Wang, H. Eric Tseng, Ding Zhao. Dynamics-Induced Commitment in Learning-Based Robotic Penalty Kicks. IEEE International Conference on Robotics and Automation (ICRA), 2027, Submitted.
- Yisen Li, Hao E. Zhang* (Co-first Author), Ruize Geng, Yves Tseng, Ding Zhao, H. Eric Tseng. SAGE: Safety-Aligned Gradient Enforcement for Human-Robot Collaboration. IEEE International Conference on Robotics and Automation (ICRA), 2027, Submitted.
- Yikai Wang, Honghao Zhu, Xiao Hu, Hao E. Zhang, Zelin Wang, Yip Fun Yeung, Ding Zhao, Lingfeng Sun. KPI: A Promptable Kernel for Physical Interaction on Humanoids. IEEE International Conference on Robotics and Automation (ICRA), 2027, Submitted.
- Hao E. Zhang, Nuo Lei, Wang Peng, Bingbing Li, Shujun Lv, Boli Chen, Zhi Wang. Bi-Level Transfer Learning for Lifelong-Intelligent Energy Management of Electric Vehicles. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(10): 16174–16187. (IF: 9.1)
- Hao E. Zhang, Ruize Geng, Yisen Li, Yaru Niu, Yikai Wang, Raihan Haque, Khalil Zbiss, Guanyang Luo, Hui-ping Wang, H. Eric Tseng, Ding Zhao. Anticipatory Robot Goalkeeping via Monotone Optimal Stopping. IEEE International Conference on Robotics and Automation (ICRA), 2027, Submitted.
- Hao E. Zhang, Ding Zhao, H. Eric Tseng. Cognition-to-Control: Multi-Agent Learning for Human-Humanoid Collaborative Transport. arXiv:2603.03768, 2026. Preprint.
- Guixiang Yang, Hao E. Zhang, Lin Qiu. Graph-Based Multi-Agent Reinforcement Learning with an Enriched Environment for Joint Ride-Sharing and Charging Optimization. Applied Energy, 2026, 405: 127220. (IF: 12.2)
- Hao E. Zhang, Guixiang Yang, Nuo Lei, Chaoyi Chen, Boli Chen, Lin Qiu. Scenario-Aware Electric Vehicle Energy Control with Enhanced Vehicle-to-Grid Capability: A Multi-Task Reinforcement Learning Approach. Energy, 2025, 335: 138189. (IF: 10.1)
- Yuhan Chen, Yuhao Liu, Nuo Lei, Chaoyi Chen, Hao E. Zhang† (Project lead & Corresponding author). Knowledge-Interposed Curriculum Reinforcement Learning for Efficient Supervisory Control Synthesis in Electric Flying Vehicles. Green Energy and Intelligent Transportation, 2026, Early Access. (IF: 21.5)
- Nuo Lei, Hao E. Zhang† (Project lead & Corresponding author), Hong Wang, Zunyan Hu, Hu Chen, Jingjing Hu, Zhi Wang. Theory-Constrained Neural Network with Modular Interpretability for Fuel Cell Vehicle Modeling. IEEE Transactions on Vehicular Technology, 2025, 74(6): 8907–8920. (IF: 7.5)
- Hao E. Zhang, Boli Chen, Nuo Lei, Bingbing Li, Rulong Li, Zhi Wang. Integrated Thermal and Energy Management of Connected Hybrid Electric Vehicles Using Deep Reinforcement Learning. IEEE Transactions on Transportation Electrification, 2024, 10(2): 4594–4603. (IF: 8.5)
- Guixiang Yang, Hao E. Zhang, Lin Qiu. Joint Taxi Dispatch and Station Pricing Optimization: A Game-Theoretic Multi-Agent Reinforcement Learning Approach via Alternating Training. Energy, 2026, Article 140715. (IF: 10.1)
- Hao E. Zhang, Jiawen Dong, Nuo Lei, Yikun Qin, Bingbing Li, Chaoyi Chen, Boli Chen. Optimal Vehicle Dynamics and Powertrain Control of Carbon-Free Autonomous Vehicles: Large Language Model Assisted Heterogeneous-Agent Learning. Energy, 2025, 338: 138786. (IF: 10.1)
- Nuo Lei, Hao E. Zhang, Jingjing Hu, Zunyan Hu, Zhi Wang. Sim-to-Real Design and Development of Reinforcement Learning-Based Energy Management Strategies for Fuel Cell Electric Vehicles. Applied Energy, 2025, 393: 126030. ESI Highly Cited Paper. (IF: 12.2)
- Hao E. Zhang, Boli Chen, Nuo Lei, Bingbing Li, Chaoyi Chen, Zhi Wang. Coupled Velocity and Energy Management Optimization of Connected Hybrid Electric Vehicles for Maximum Collective Efficiency. Applied Energy, 2024, 360: 122792. (IF: 12.2)
- Nuo Lei, Hao E. Zhang, Hong Wang, Zhi Wang. An Improved Co-Optimization of Component Sizing and Energy Management for Hybrid Powertrains Interacting with High-Fidelity Model. IEEE Transactions on Vehicular Technology, 2023, 72(12): 15585–15596. (IF: 7.5)
- Bingbing Li, Weichao Zhuang, Hao E. Zhang, Hao Sun, Haoji Liu, Jianrun Zhang, Guodong Yin, Boli Chen. Traffic-Aware Ecological Cruising Control for Connected Electric Vehicle. IEEE Transactions on Transportation Electrification, 2024, 10(3): 5225–5240. (IF: 8.5)
- Hao E. Zhang, Nuo Lei, Boli Chen, Bingbing Li, Rulong Li, Zhi Wang. Modeling and Control System Optimization for Electrified Vehicles: A Data-Driven Approach. Energy, 2024, 310: 133196. (IF: 10.1)
- Hao Sun, Bingbing Li, Hao E. Zhang, Li Dai, Giuseppe Fedele, Weichao Zhuang, Boli Chen. Ecological Electric Vehicle Platooning: An Adaptive Tube-Based Distributed Model Predictive Control Approach. IEEE Transactions on Transportation Electrification, 2024, 11(1): 1048–1060. (IF: 8.5)
The above are selected recent publications from the past 3 years. A complete publication list is available on my Google Scholar homepage.
🎖 Honors and Awards
- 2026 Best Paper Award at International Symposium on Advanced Vehicle Control
- 2026 Best Paper Award at IROS 2026 Workshop on Physical World Models for Scaling Embodied AI
- 2026 Oral Presentation at International Conference on Machine Learning
- 2026 Gold Reviewer for International Conference on Machine Learning
- 2024 Plenary Talk at 2024 China SAE Annual Conference on Advanced Powertrains
- 2024 “Shuimu Tsinghua Scholar” Talents Program, Tsinghua University
- 2024 Outstanding Doctoral Dissertation Award, Tsinghua University
- 2024 Outstanding Ph.D. Graduate (top 4%), Tsinghua University
- 2023 Comprehensive Excellence Scholarship, Tsinghua University
- 2022 Comprehensive Excellence Scholarship, Tsinghua University
- 2021 Excellent Student Leader, Tsinghua University
- 2021 Comprehensive Excellence Scholarship, Tsinghua University
- 2020 Comprehensive Excellence Scholarship, Tsinghua University
- 2018 National Scholarship, Ministry of Education of China
- 2018 Best Paper Award in the 2018 IEEE ACES Conference in Denver, U.S.
- 2017 National Scholarship, Ministry of Education of China
- 2016 National Scholarship, Ministry of Education of China
📚 Service
Editor
- Associate Editor: IEEE Intelligent Vehicles Symposium (IEEE IV) 2026, sponsored by The IEEE Intelligent Transportation Systems Society (ITSS), Ann Arbor, USA
- Associate Editor: The IEEE International Conference on Intelligent Transportation Systems (ITSC) 2026, sponsored by The IEEE Intelligent Transportation Systems Society (ITSS), Naples, Italy
- Associate Editor: IEEE Intelligent Vehicles Symposium (IEEE IV) 2027, sponsored by The IEEE Intelligent Transportation Systems Society (ITSS), Perth, Western Australia
- Guest Editor: Biomimetics, Special Issue: Visual Perception and Motor Control for Intelligent Human–Robot Interaction
- Guest Editor: Frontiers in Robotics and AI, Special Issue: Cooperative Autonomous Transportation Systems: Embodied Multi-Agent Intelligence from Simulation to Real-World Deployment
- Guest Editor: Electronics, Special Issue: Eco-Safe Intelligent Mobility Development and Application
Reviewer
- Journal Reviewer: 1. IEEE Transactions on Intelligent Transportation Systems (IF: 9.1); 2. IEEE Transactions on Intelligent Vehicles (IF: 14.3); 3. IEEE Transactions on Transportation Electrification (IF: 8.5); 4. IEEE Transactions on Visualization and Computer Graphics (IF: 6.8); 5. IEEE Open Journal of Vehicular Technology (IF: 6.6); 6. Renewable and Sustainable Energy Reviews (IF: 18.0); 7. Applied Energy (IF: 12.2); 8. Energy (IF: 10.1); 9. Energy Conversion and Management (IF: 11.8); 10. Sustainable Energy, Grids and Networks (IF: 5.7); 11. Journal of Cleaner Production (IF: 10.7); 12. Journal of Energy Storage (IF: 10.7); 13. Journal of Power Sources (IF: 8.4); 14. Green Energy and Intelligent Transportation (IF: 21.5); 15. Robotics and Autonomous Systems (IF: 6.0); 16. Engineering Applications of Artificial Intelligence (IF: 9.0); 17. eTransportation (IF: 18.7)
- Conference Reviewer: 1. International Conference on Machine Learning (ICML); 2. Annual Conference on Neural Information Processing Systems (NeurIPS); 3. International Conference on Learning Representations (ICLR); 4. AAAI Conference on Artificial Intelligence (AAAI); 5. IEEE Intelligent Vehicles Symposium (IV); 6. IEEE Intelligent Transportation Systems Conference (ITSC)
Teaching
- Guest Lecturer (Designed and delivered 6 lectures), EE5329, Topics in Systems Engineering (Reinforcement Learning and Control), UT Arlington, Spring 2026
- Guest Lecturer (Project-based instruction), 80150183, Fundamentals of Automotive Powertrains, Tsinghua University, Fall 2023
- Teaching Assistant, 40150420, Student Research Training (SRT), Tsinghua University, Fall 2022
- Teaching Assistant, 80150042, Frontiers in Vehicle System Dynamics and Control, Tsinghua University, Fall 2021
Mentorship
- Since 2024 (during Postdoc), have independently provided mentorship to postgraduate and undergraduate students (research assistants): Mr. Ruize Geng (JHU), Mr. Yisen Li (UPenn), Mr. Changwei Yao (CMU), MS. Jiayi Liu (Tsinghua University), Mr. Yuhan Chen (UC Berkeley), Mr. Kaifeng Jia (Cornell University), Ms. Xinyi Zhao (NYU), Ms. Siting Xu (Duke), Mr. Jiarui Zhang (HKU), Ms. Guixiang Yang (Zhejiang University), etc. More than half of the mentees have published papers in top-tier conferences and journals, with me serving as the corresponding/last author on multiple projects. I am actively recruiting research assistants and students interested in embodied AI.
- Since 2020, assisted in the supervision of 5 Ph.D. students, 13 master’s students; mentored over a dozen undergraduate students, their work received multiple honors including Tsinghua University and Beijing Outstanding Undergraduate Thesis Awards.